Research & projects
Mostly university work — lab research and competition entries — plus tools I build and maintain on my own. Grouped so you can tell which is which.
Independent
Open-source tools I build and maintain on my own.
MCP Servers for Agentic Vehicle Control
A set of Model Context Protocol servers that give an AI assistant real, typed control of a MAVLink vehicle — arm, take off, navigate, read telemetry — plus the terrain, vision and camera context it needs to make those calls sensibly.
Read →02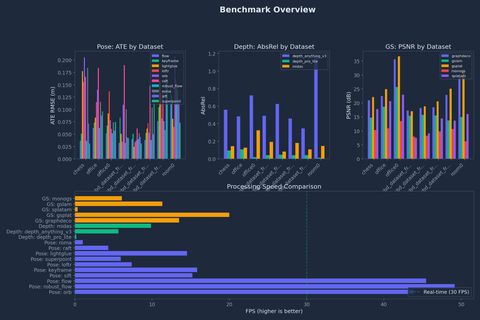
Real-Time Gaussian Splatting for Vehicles
A framework that streams RGB-D from a camera, drone or dataset and builds a 3D Gaussian-splat map as it goes, with a browser dashboard and an automated benchmark harness across five splatting engines.
Read →Lab research
University lab work: the Reconfigurable Space Computing Laboratory, the Cal Poly Pomona aerospace department, a US Navy research program, and bench studies I ran on my own.
Reconfigurable CubeSat Clusters
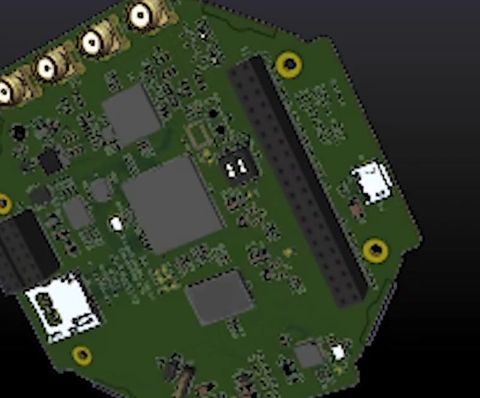
A compute and communications stack that turns a swarm of 1U CubeSats into a single elastic cluster, with FPGA payloads that change function in orbit and workloads that migrate between satellites in seconds.
Read →02
Natural-Language Flight Control
A chat-to-fly interface for UAV operators: spoken or typed instructions translated directly into flight commands by a language model running on the aircraft, not in a datacentre.
Read →03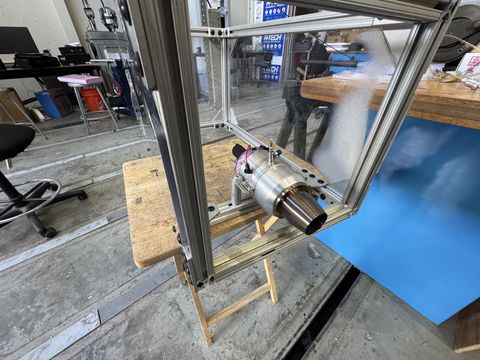
Turbine-Powered VTOL Platform
A VTOL airframe driven by twin JetCat P60 micro-turbines instead of electric rotors: over 13 kg of combined thrust and fixed-wing cruise speeds, while keeping multirotor agility for vertical take-off.
Read →04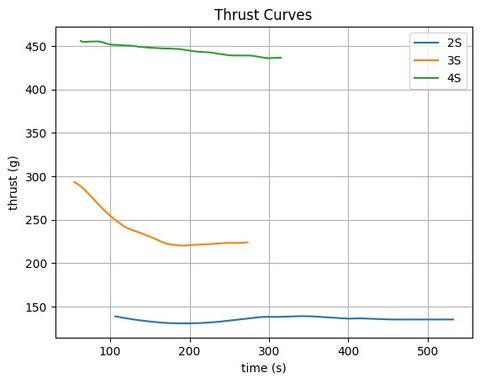
40 mm EDF Thrust and Thermal Characterization
A thrust-stand study of a 40 mm electric ducted fan across 2S, 3S and 4S packs — measuring what the unit actually delivers over a full discharge, and what it costs thermally.
Read →Competition
NASA MINDS entries, built to a brief and judged against other teams. Four placed. A few stopped at a design review, and say so.
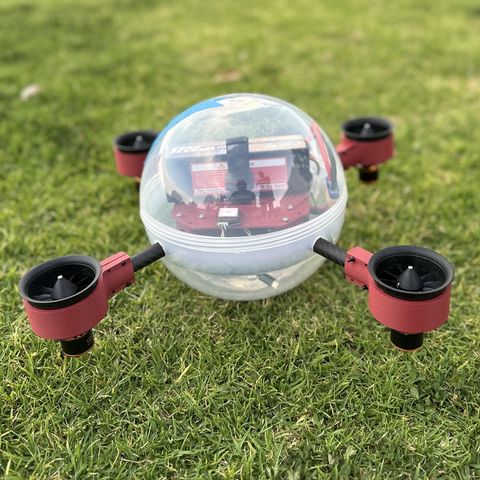
Air-and-Water Autonomous Vehicle
AQUAD: a single vehicle that flies to a site, submerges, maneuvers underwater and returns to the air, on one charge. Built against a brief targeting ocean worlds such as Europa.
Read →02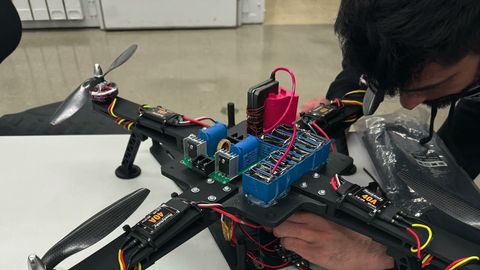
Wireless Power and Data Transfer
Paired resonant Tesla coils beaming power and low-frequency data across a gap with no conductor between them, and the electromagnetic compatibility engineering needed to keep nearby avionics alive.
Read →03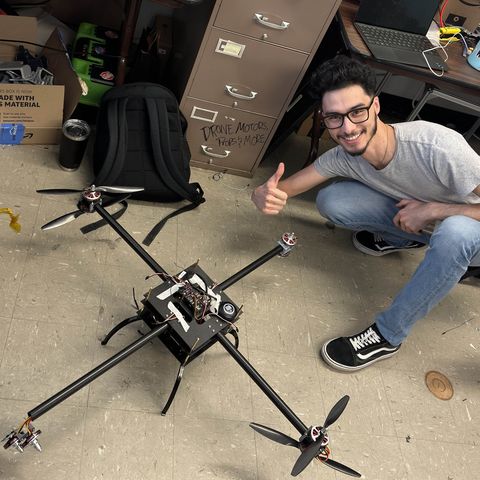
Autonomous Aerial Docking and Recharge
A heavy-lift carrier UAV acting as an airborne charging hub and data relay, letting micro-drones dock in flight to recharge, offload sensor data and borrow GPU cycles.
Read →04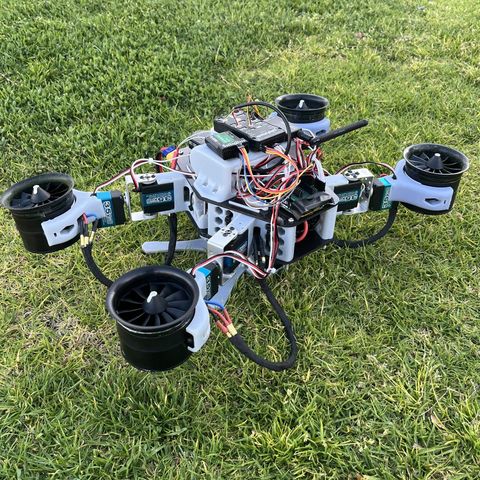
Morphing-Geometry Multirotor
A multirotor whose thruster pods pivot and slide on servo-driven rails, shifting from a wide-span cruise configuration to a compact footprint that fits through doorways and pipe racks.
Read →05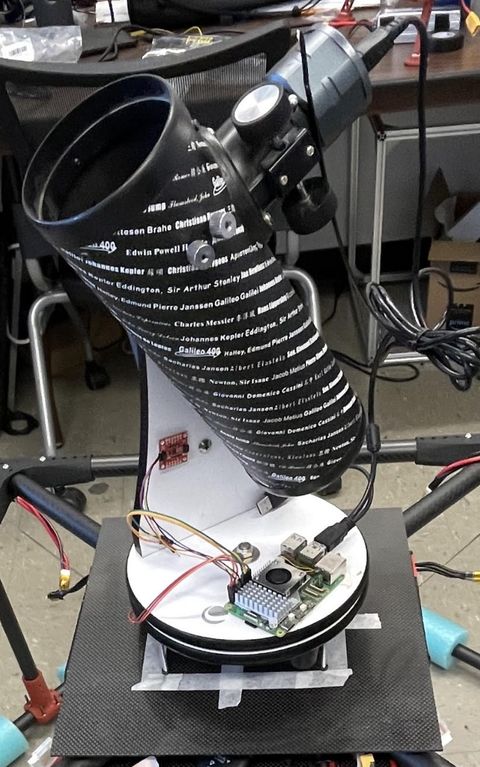
Airborne Observatory with On-Board Plate Solving
A UAV that lifts a stabilized telescope clear of the worst of the atmosphere and works out what it is looking at on board, without needing a ground station in the loop.
Read →06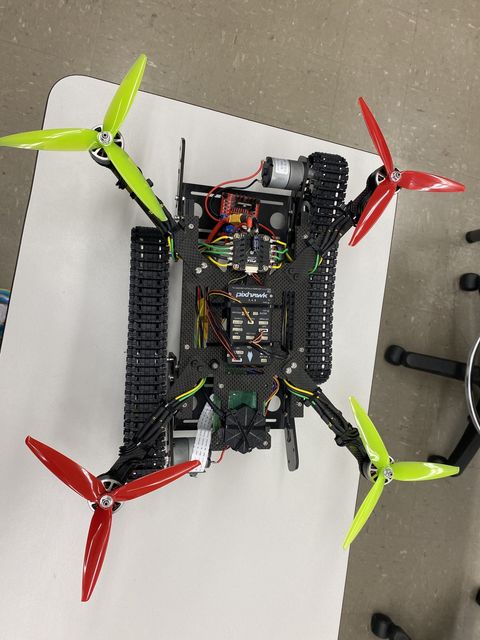
Air-and-Ground Hybrid Vehicle
One vehicle that drives across terrain it can cross and flies over terrain it cannot, with both propulsion systems sharing a single airframe, battery and controller.
Read →07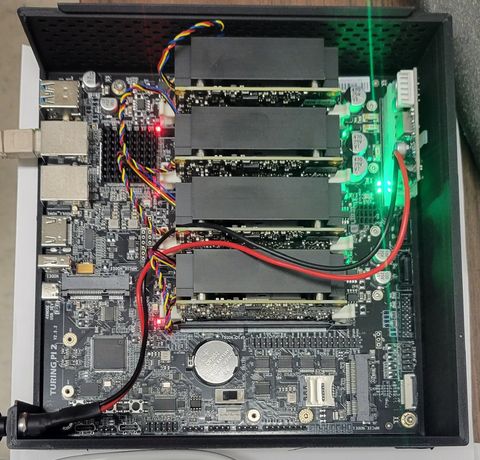
Post-Quantum Telemetry for Spacecraft Links
Encrypting and signing a live vehicle telemetry link with lattice cryptography, on RISC-V compute small enough and cheap enough to fly, inside a millisecond budget.
Read →08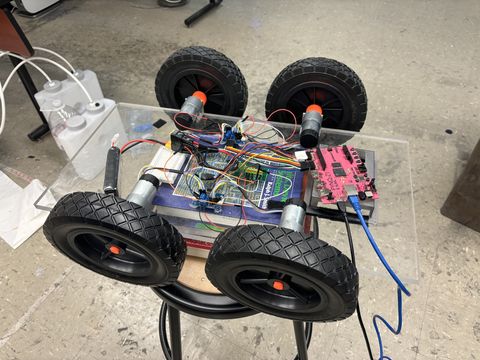
Encrypted Command Link for a Ground/Air Robot Pair
Ascon protecting the command channel between a ground vehicle and an aircraft, with an encrypted heartbeat that fails both vehicles safe the moment the link dies.
Read →09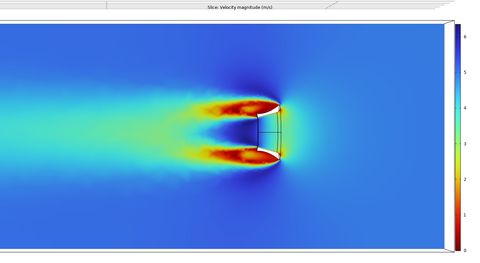
Electrohydrodynamic Thruster Demonstrator
A solid-state propulsion demonstrator with no moving parts, producing thrust by accelerating ions through a high-voltage field instead of burning propellant.
Read →10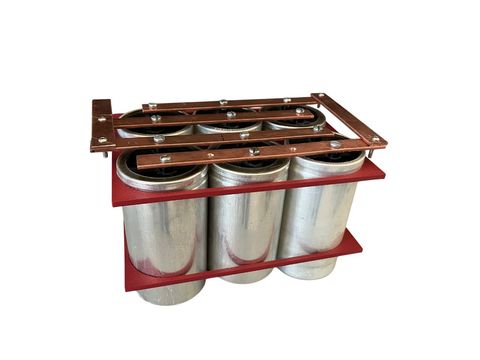
Electromagnetic Payload Launcher
A pulse-power launcher that throws a small glider or instrument package to terrain a rover cannot reach, using a capacitor bank rather than a propellant charge.
Read →11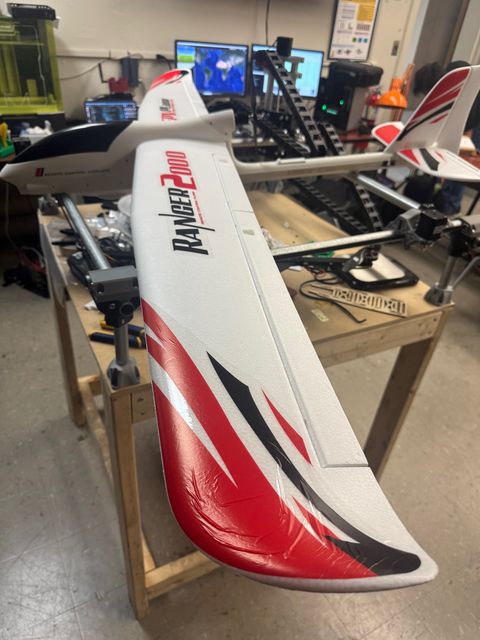
Solar-Electric Fixed-Wing Endurance Platform
A fixed-wing UAV whose wing-mounted array charges the flight pack in the air, pushing endurance past what the battery alone would give.
Read →