Work · NASA MINDS competition, ocean-world exploration brief
Air-and-Water Autonomous Vehicle
NASA MINDS 2025 - Exceptional Experimental Design
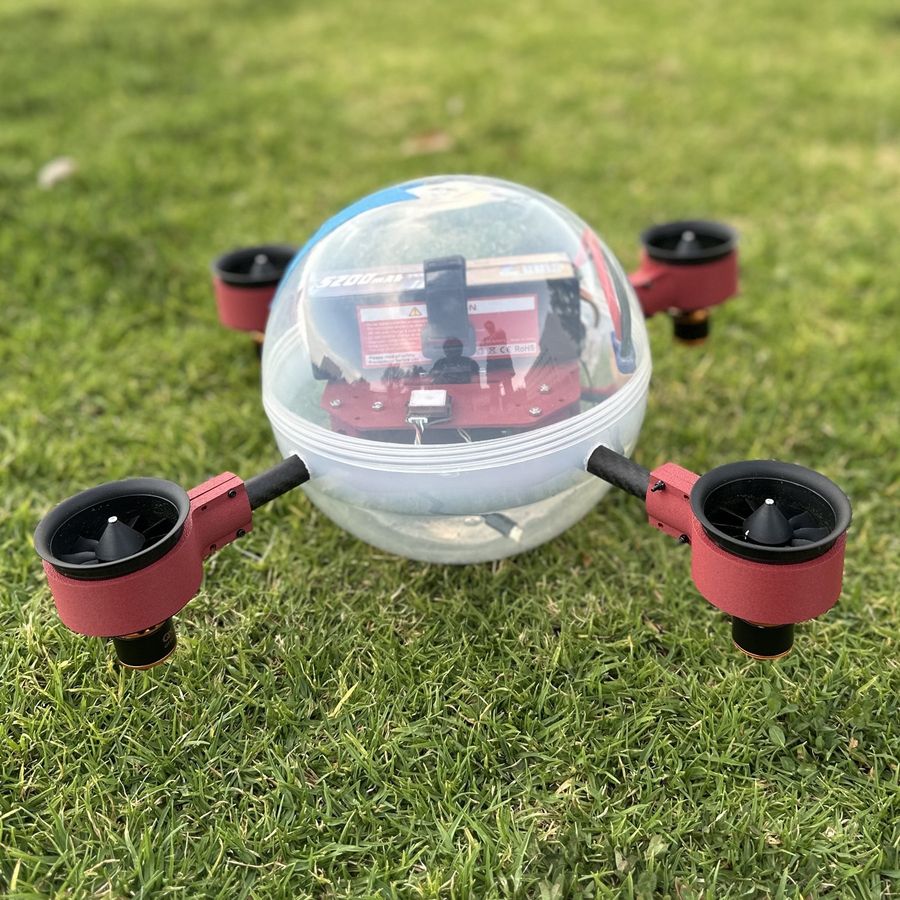
AQUAD: a single vehicle that flies to a site, submerges, maneuvers underwater and returns to the air, on one charge. Built against a brief targeting ocean worlds such as Europa.
The problem
Air and water impose opposite requirements. Propulsion efficient in one medium is wrong in the other, the structure must tolerate pressure while staying light enough to fly, and the controller has to remain stable through the transition itself.
What I did
Used lightweight 50 mm EDF thrusters selected to produce usable thrust in both media, on a pressure-tolerant frame kept within the flight weight budget.
Wrote adaptive control firmware that reconfigures the control loop as the vehicle changes medium, rather than treating flight and dive as separate vehicles.
Instrumented the whole thing with real-time dashboards over MAVLink so behavior through the transition could actually be observed.
Result
Aerial insertion, subsurface maneuvering and vertical extraction on a single charge. Recognized for Exceptional Experimental Design at NASA MINDS 2025.
From the report
Bench photographs and measured data from the project's own report.