Work · NASA MINDS competition
Morphing-Geometry Multirotor
NASA MINDS 2024 - Semi-Finalist
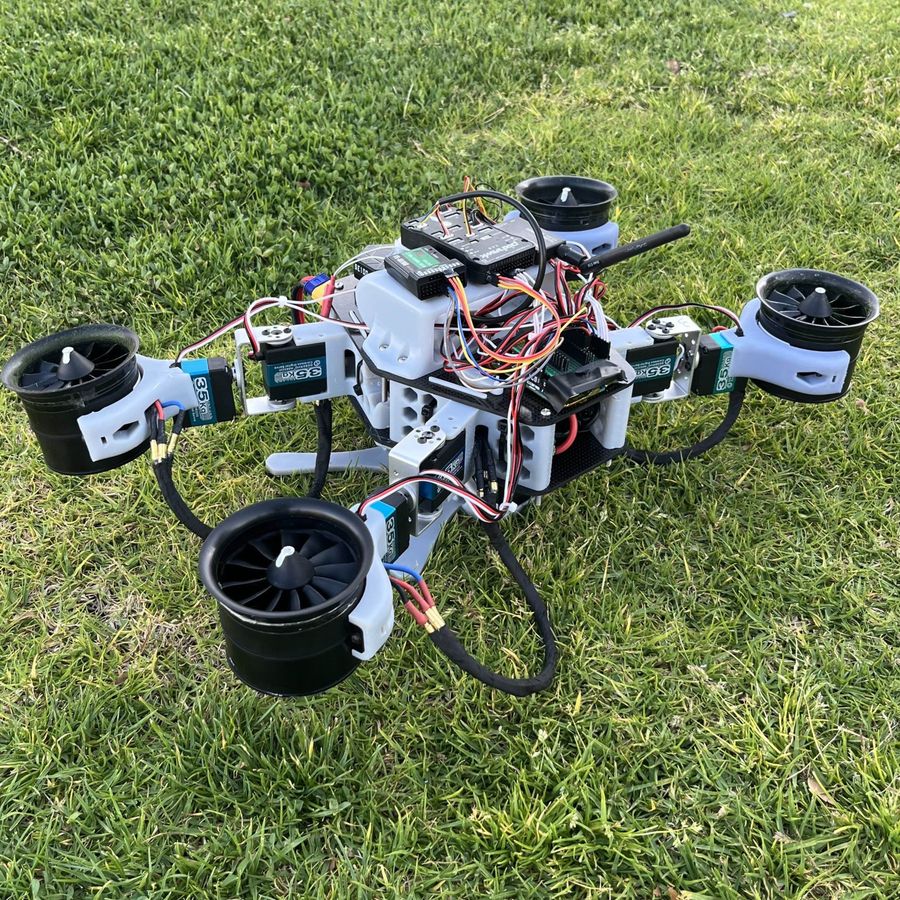
A multirotor whose thruster pods pivot and slide on servo-driven rails, shifting from a wide-span cruise configuration to a compact footprint that fits through doorways and pipe racks.
The problem
Span is a direct trade: wide is efficient in cruise, narrow is what gets you through a doorway or a culvert. Fixed-geometry aircraft have to pick one and live with it.
What I did
Mounted the thruster pods on servo-driven rails so the airframe changes geometry in seconds, optimizing lift-to-drag for range and then tucking the rotors close to the fuselage for access.
Made the motor arms modular and swappable so the same airframe serves several mission profiles without a rebuild.
Result
One vehicle covering both long-range flight and confined-space inspection, aimed at industrial inspection where access is the binding constraint. Semi-Finalist at NASA MINDS 2024.
From the report
Bench photographs and measured data from the project's own report.